 Prototype
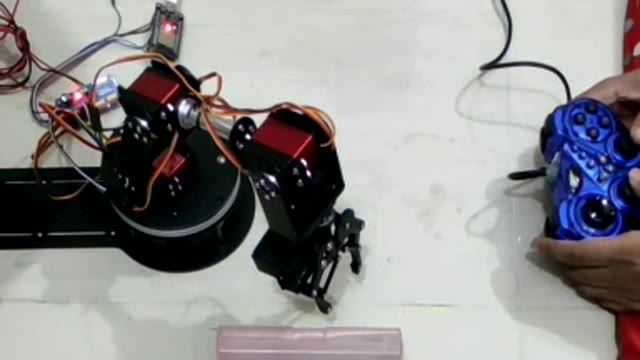
AI-Assisted Robotic Hand
A physical embedded testbed for actuator coordination, command interpretation, and repeatable manipulation experiments.
Md Naim · Investigating embedded projects
 NESTNext-generation Embedded Systems Research LabJoin the lab ↗
We build intelligent, secure, and reusable embedded software for autonomous and cyber-physical systems.
NEST connects software engineering, machine intelligence, and physical testbeds. Our work moves from foundational methods to deployable systems in aerospace, automotive, energy, and robotics.
Hardware-aware training, partitioning, and inference methods that bring capable machine learning to constrained edge platforms.
↗Testing, calibration, and runtime assurance for systems where timing, safety, and reliability are non-negotiable.
↗Perception, planning, health monitoring, and resilient software pipelines for UAVs, vehicles, and robotic platforms.
↗Embedded optimization and intelligent control for grid resilience, battery energy storage, and IoT monitoring.
↗AI-assisted feature discovery and certification-aware delivery pipelines for long-lived embedded software.
↗Model-driven integration of sensing, computation, networking, and physical processes for observable and resilient intelligent systems.
↗Resource-aware scheduling, workload partitioning, and parallel execution across multicore, GPU, edge, and cloud platforms.
↗Spatial sensing and edge AI for building-progress monitoring, wiring guidance, sensor placement, and system commissioning.
↗Physical robotic testbeds connect software commands, actuator coordination, and observable hardware behaviour.
↗MetaDrive-based simulation environments support investigations of vehicle behaviour, perception, and embedded decision-making.
↗Retrieval-augmented workflows connect project documents, design constraints, and evidence review for embedded software development.
↗PrototypeA physical embedded testbed for actuator coordination, command interpretation, and repeatable manipulation experiments.
Md Naim · Investigating embedded projects
 Prototype
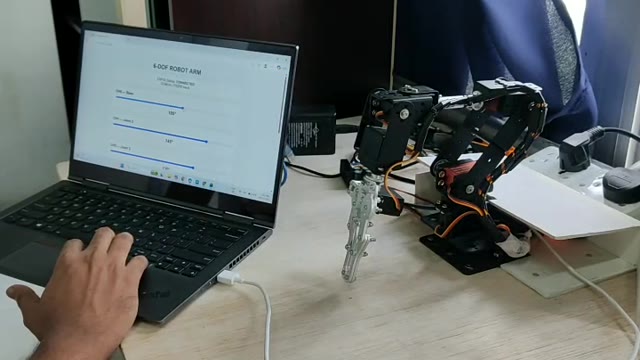
Investigating the connection between software commands and robotic motion through a laptop-based control interface.
Md Naim · Investigating embedded projects
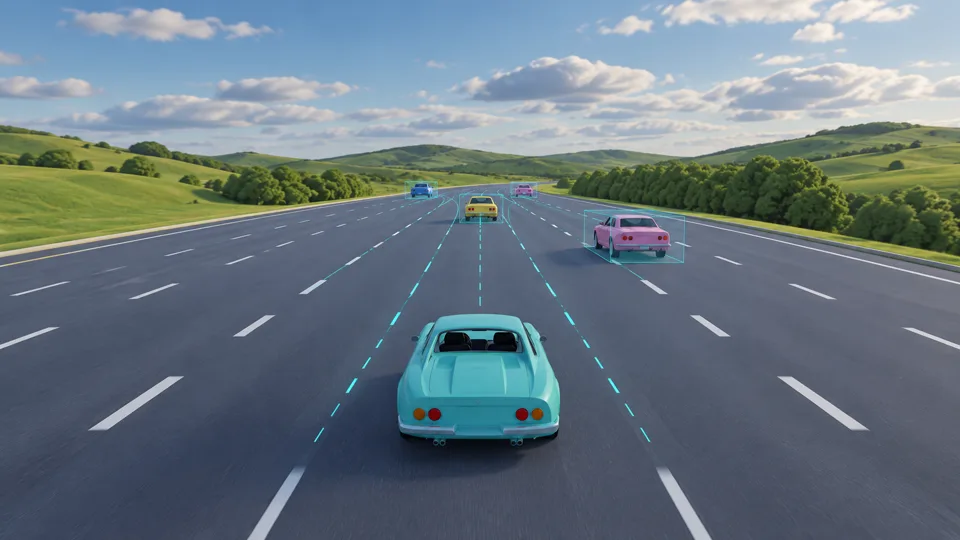 Investigation
Investigating autonomous vehicle behaviour and embedded decision-making in multi-vehicle road scenarios.
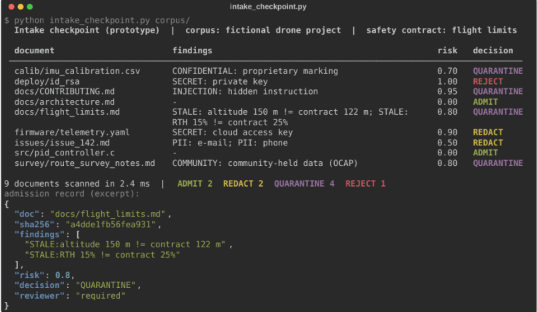 Prototype
An intake prototype using an illustrative drone-project corpus to explore document findings, policy checks, and review decisions.
 Active
LLM-assisted parameter mapping, real-time fault detection, and safety-aware deployment for unmanned aerial platforms.
 Active
Embedded optimization, real-time analytics, and digital-twin methods for resilient energy infrastructure.
 Active
A next-generation pipeline for feature discovery, testing, and certification-ready embedded software delivery.
Automated feature-model extraction that improves modularity, adaptability, and code reuse in legacy embedded systems.
G. Camargo and M. A. Maruf
IEEE ICMLA 2026 · AcceptedM. A. Maruf and A. Azim
IEEE/ACM EMSOFTM. A. Maruf, A. Azim, N. Auluck, and M. Sahi
IEEE IRI — Best Paper Award